


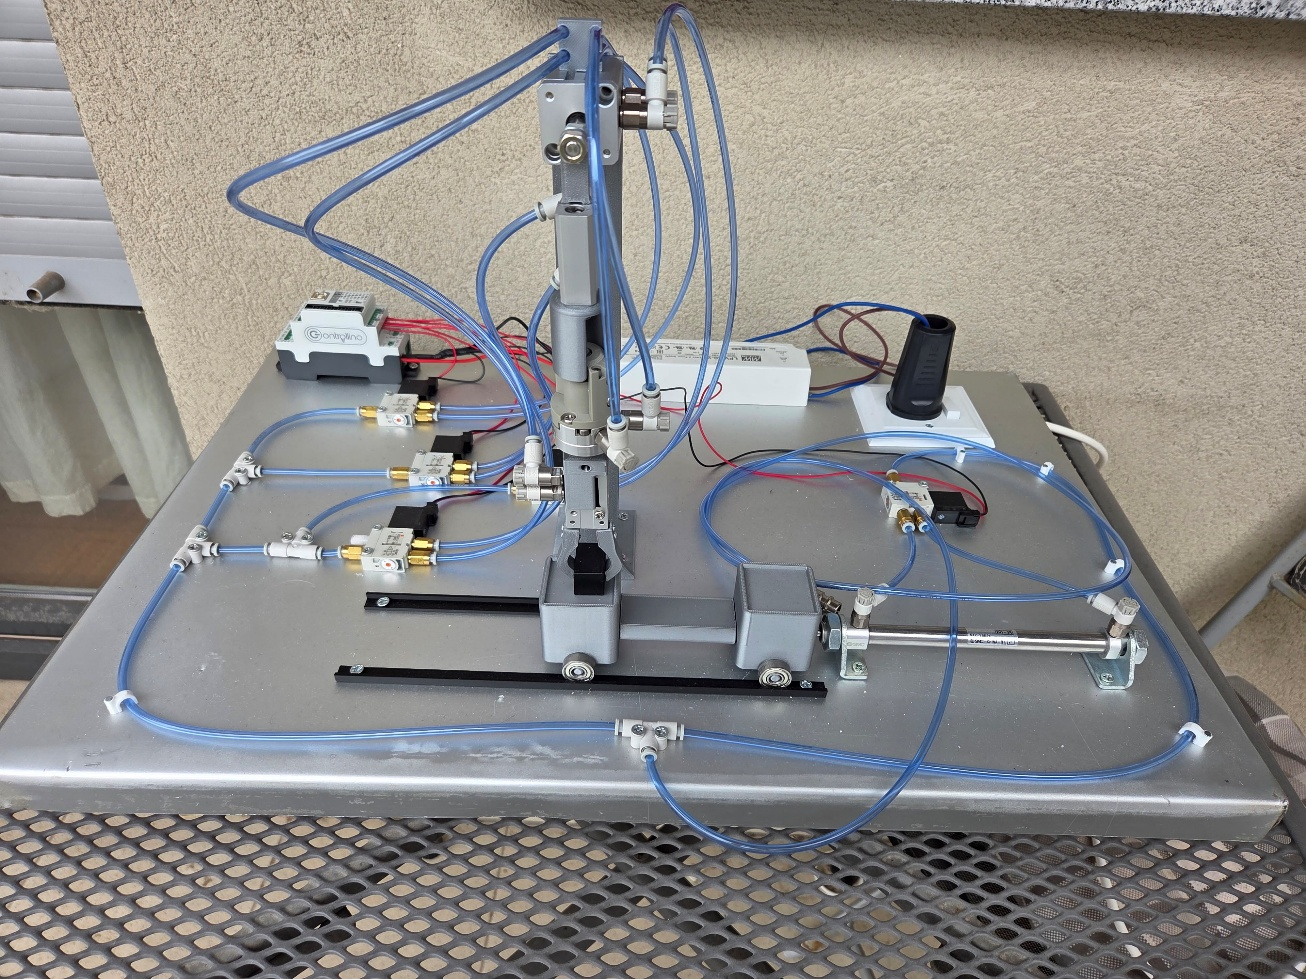
Miniature pneumatic manipulator
Authors: NIKO RATKOVIĆ
Menthor: ŽELJKO ŠITUM
Companies /Institutions: University of Zagreb, Faculty of Mechanical Engineering and Naval Architecture
Country: CROATIA
e-mail: nr251825@fsb.hr
A pneumatic manipulator designed for the automated gripping, transfer, and placement of objects has been engineered and constructed. The system comprises multiple pneumatic actuators that enable horizontal and vertical movement, rotation, and object gripping via a pneumatic gripper. System control is managed by a CONTROLLINO Mini control unit, which coordinates the operation of solenoid valves according to a predefined sequence. A distinctive feature of the manipulator is the combination of various types of pneumatic actuators into a single automated system, along with the ability to easily adjust the operating sequence and mode by modifying the control program. Pneumatic actuation ensures fast, reliable, and safe movement execution, while offering a simple design and ease of maintenance. The system is primarily intended for education and the demonstration of principles regarding pneumatics, automation, and mechatronics; however, it also serves as a model of an industrial “pick-and-place” system for handling small objects.

