




Self-balancing mobile robot with person-following capability
Authors: LOVRO MRAZ
Menthor: ŽELJKO ŠITUM
Companies /Institutions: University of Zagreb, Faculty of Mechanical Engineering and Naval Architecture
Country: CROATIA
e-mail: lm246267@student.fsb.unizg.hr
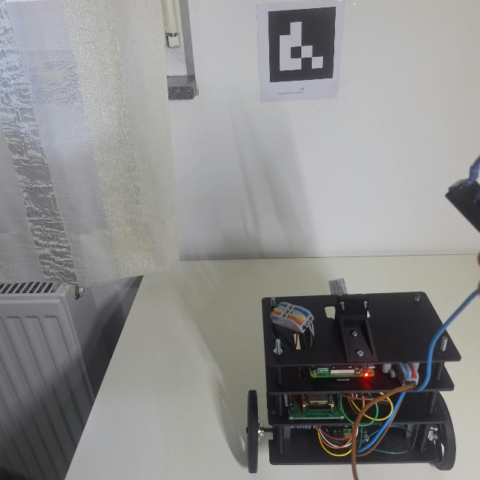
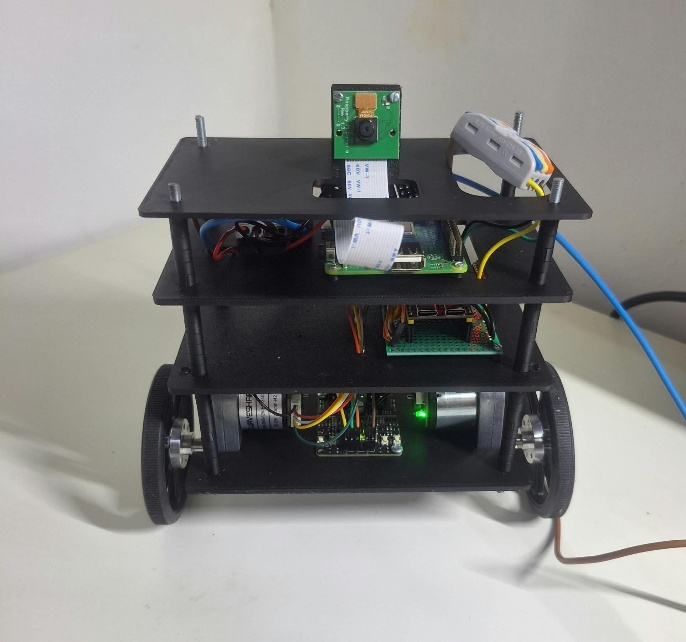
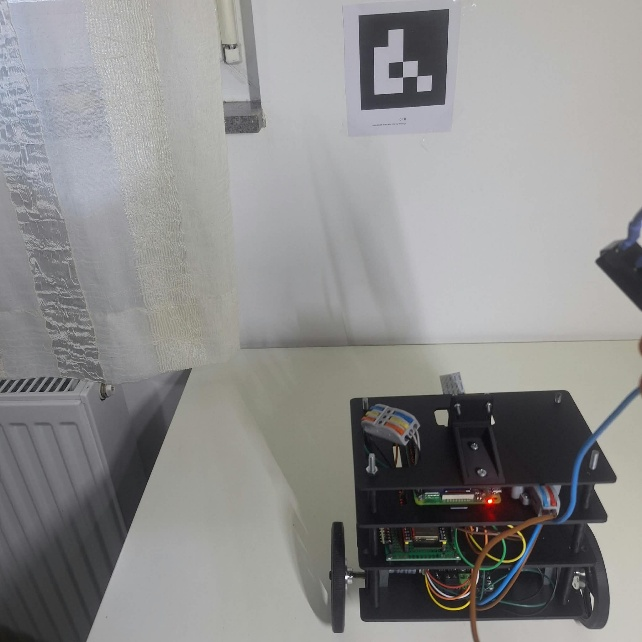
This innovation is a two-wheeled, self-balancing robot designed to autonomously follow a person or a specific target. The robot maintains an upright position by regulating motor speed and rotation direction based on data from an inertial sensor, while encoders track its movement and position. A key feature of the system is the integration of high-speed balance control on an ESP32 microcontroller with computer vision processing on a Raspberry Pi. A camera detects a visual marker, determines its position and distance, and commands the robot’s direction and speed. This division of tasks enables simultaneous, stable balancing and target tracking in real time. The robot features a modular design built from readily available commercial components, facilitating modifications and its use as a development platform for autonomous mobile robotics, education, and the testing of various control algorithms.

