




Myoelectric bionic hand powered by stepper motors
Authors: PATRICK ĆURIĆ
Menthor: ŽELJKO ŠITUM
Companies /Institutions: University of Zagreb, Faculty of Mechanical Engineering and Naval Architecture
Country: CROATIA
e-mail: pc524573@fsb.hr
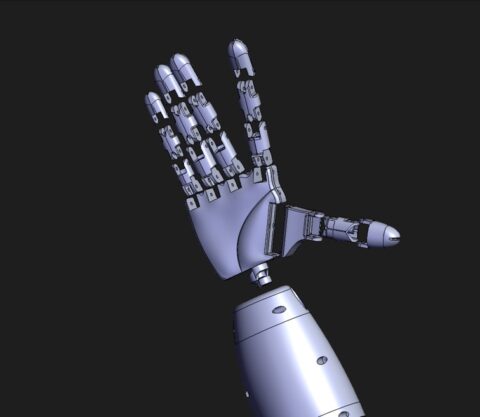
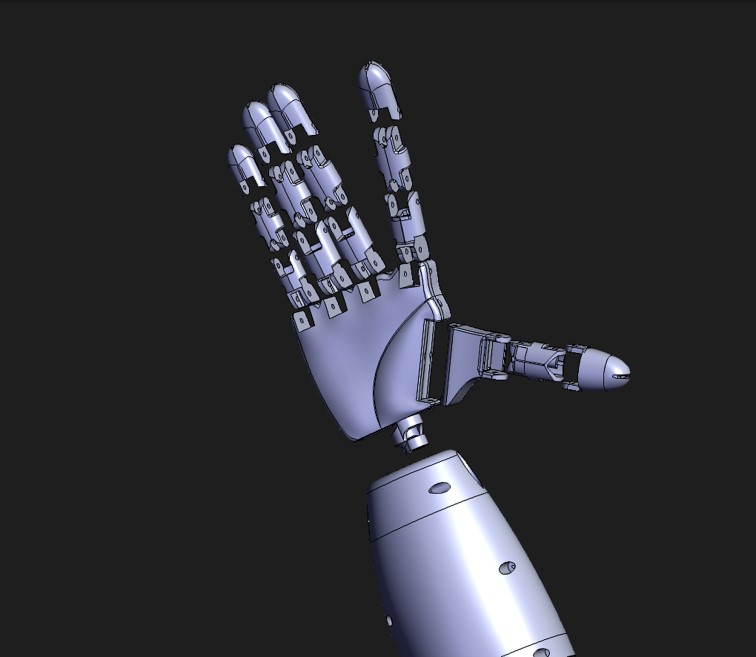
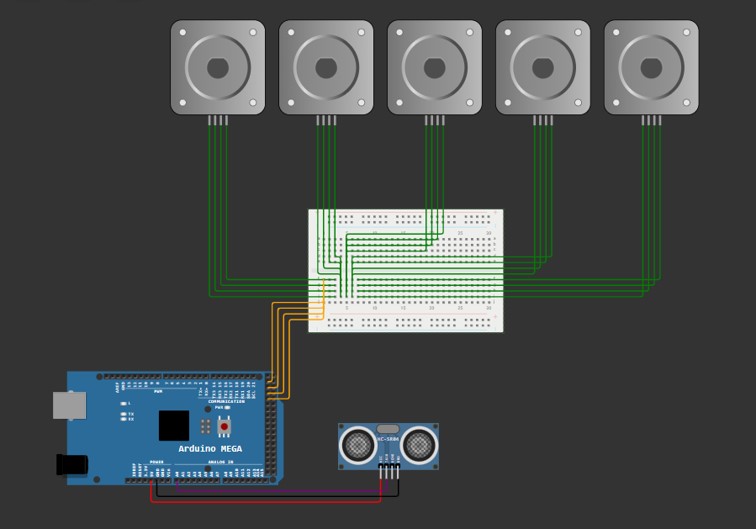
The innovation is a bionic hand prototype created using 3D printing technology and optimized, lightweight materials, designed for the functional grasping of objects. System control is managed via a control board that processes input signals from EMG sensors detecting muscle activity and coordinates the operation of five stepper motors. The mechanism employs a tendon-like drive system using cables that extend from the motors to the fingertips, enabling synchronized hand closure.
The prototype is primarily intended to serve as an affordable replacement for amputated biological limbs by interpreting the user’s neuromuscular impulses. Beyond prosthetics, the system holds potential for augmenting human capabilities or developing advanced industrial manipulators. Future development will focus on the software implementation of independent finger movement and the integration of sensors for more precise control, including the potential incorporation of brainwave (EEG) reading.

